Sitemap
A list of all the posts and pages found on the site. For you robots out there, there is an XML version available for digesting as well.
Pages
Posts
portfolio
Publication on AMOS 2026: Dichotomizing Temporarily Bound Objects Using Capture States
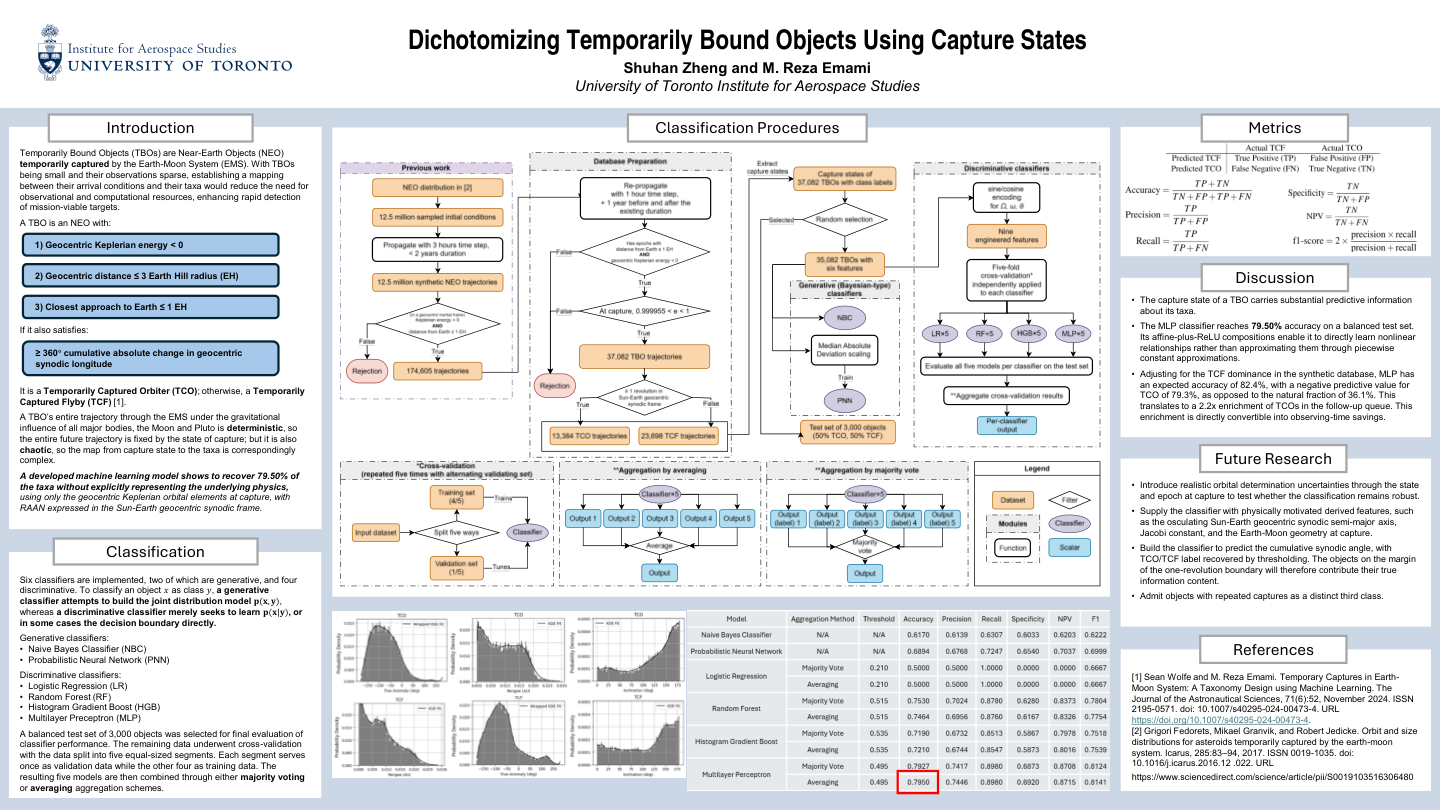
Accepted for presentation at the AMOS 2026 conference as first author. My research focuses on using machine learning to predict an asteroid’s dynamical characteristics from its state at the moment it is captured by the Earth-Moon system.
Read the paper or view the conference poster.
Catalog Acquisition and Compilation tool
Autonomous data retrieval, sanitizing, and management pipeline with user interface API. Scalable scientific database solution designed for hierarchical and relational data.
Project repository: https://github.com/ThisisShoo/GMAT-Monte-Carlo-Propagator
GFDL - General Flight Dynamics Library
GFDL is a modular software platform with swappable backend physics engines and astrodynamics libraries, for deterministic spacecraft mission analysis and flight planning. Supports GMAT, SPICE, Orekit, and more. It is architecturally designed to interface with both humans and AI orchestrators, empowering mission analysis through a single natural language prompt.
The demonstration here is a mission from Low Earth Orbit (LEO) to Geosynchronous Earth Orbit (GEO). Mission specifications were communicated to an AI coding assistant, which generated the mission specification sheets, and executed the full pipeline without human intervention or making guesses. The in-house developed targeter autonomously computed the most fuel-efficient flight plan from an inclined LEO to an equatorial GEO using impulse burns. The flight path is propagated using NASA’s General Mission Analysis Tool (GMAT) as the simulation backend, then rendered as an interactive 3D scene.
Follow the project development on GitHub: https://github.com/ThisisShoo/GFDL
GMAT Automation for Asteroid Trajectory Prediction
Monte Carlo simulation of real asteroid trajectories for prediction of future Earth encounters with uncertainties.
Project repository: https://github.com/ThisisShoo/GMAT-Monte-Carlo-Propagator
Nonlinear Control Theory Course Paper
A study on stability and station-keeping near the Earth-Moon $L_2$ point, using the planar Circular Restricted Three Body Problem (CRTBP). This paper examined a planar Lyapunov orbit scenario from a control theory perspective, demonstrating that the $L_2$ Lyapunov orbits are indeed unstable. This paper then demonstrates that a simple linear closed loop controller can counter large perturbations and maintain the spacecraft flight parameters within a given flight envelope.